MRSI is not one die bonder with a single accuracy or process specification. The product family includes platforms developed for different combinations of placement accuracy, flip-chip assembly, epoxy attach, eutectic bonding, force control and production automation.
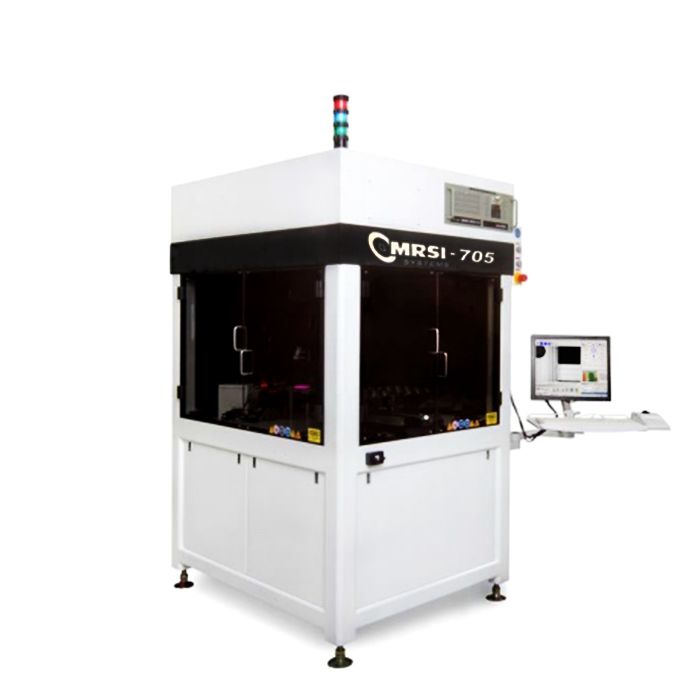
Current MRSI platforms range from 0.5 μm to 5 μm placement classes. Earlier machines such as the MRSI-605 and MRSI-705 remain available on the used-equipment market, but their installed functions can differ substantially even when the model name is the same.
A used MRSI die bonder should therefore be selected by the required assembly process first and by model name second. Accuracy, bonding method, material input, automation and included tooling all need to match the intended product.
Where MRSI Die Bonders Fit
MRSI platforms are particularly relevant when one machine must handle several component types, material inputs or bonding processes. Typical projects involve more than repetitive placement of one die onto one standard leadframe.
The platform becomes useful when the process includes one or more of the following:
Several dies or optical components within one assembly
Different pickup tools for different component geometries
Wafer, waffle pack, Gel-Pak, tray or tape-fed component input
Face-up and flip-chip placement within the same product
Epoxy dispensing or stamping before placement
Eutectic bonding with controlled heat and scrub
Low-force handling of fragile III-V or MEMS devices
In-situ UV curing to limit movement after alignment
Frequent product changes during development or low-volume production
Not every MRSI machine includes these functions. They describe the range of available platform configurations, not the standard specification of every used unit.
MRSI Model Families
| Model Family | Published Placement Class | Production Position | Configuration to Confirm |
|---|---|---|---|
| MRSI-S-HVM | ±0.5 μm @ 3σ and ±1.5 μm @ 3σ operating modes | Submicron flip-chip and integrated photonics volume production | Accuracy mode, dual gantry, direct-alignment optics, wafer handling and installed process modules |
| MRSI-LEAP | Model-specific high-accuracy configuration | High-volume production with published pick-and-place output above 1,000 UPH | Wafer capacity, multi-tool system, conveyor, dispensing, UV and flip-chip configuration |
| MRSI-HVM1 / MRSI-H1 | 1 μm class | High-precision flip-chip assembly, with HVM configurations focused on production automation | Machine generation, accuracy package, material handler, tool changer and bonding modules |
| MRSI-HVM / MRSI-H | 1.5 μm class | Flexible high-accuracy assembly; HVM versions add production-oriented automation | Exact suffix, head configuration, material input, optics and process options |
| MRSI-M3 | 3 μm class | Complex multi-component assembly from development through automated production | Up-look camera, force control, wafer handling, tool banks, dispensing and eutectic options |
| MRSI-705 | 5 μm class | Flexible die bonding for development, product introduction and low- to medium-volume assembly | Vision, force range, dispensing, eutectic, flip-chip and material-presentation options |
| MRSI-705HF | 5 μm class | High-force and heated-head processes | Published capability includes up to 500 N force and top heating up to 400°C; verify the complete HF configuration |
| MRSI-605 / 605 AP | Legacy model; use exact machine documentation | Established microelectronics and optoelectronic assembly processes | Model suffix, controller generation, software, optics, process modules and available tooling |
The accuracy class narrows the search but does not complete the selection. An automated 1.5 μm HVM platform and a flexible 3 μm MRSI-M3 address different production conditions even when both can handle similar components.
Start with the Assembly Process
The required bonding process determines which modules must be present on the machine. A model brochure may list several available processes, but a used machine normally contains only the options selected by its original owner.
| Required Process | Installed Equipment | Process Verification |
|---|---|---|
| Standard Die Placement | Suitable pickup head, bond head, vision system, workholder and component input | Repeated pickup, alignment and placement with comparable dies and substrates |
| Flip-Chip Assembly | Up-look vision, bottom-feature alignment, compatible pickup tools and face-down placement functions | Alignment and placement after the die has been presented in the required orientation |
| Epoxy Dispensing | Dispensing pumps, controller, height sensing, needles and material-delivery components | Deposit position, volume, repeatability and placement after dispensing |
| Epoxy Stamping | Stamping well, stamping tools and compatible tool-change positions | Dot transfer, dot size, tool cleaning and deposit consistency |
| Eutectic Bonding | Heated stage, temperature control, cover gas, scrub and compatible fixtures | Temperature profile, scrub motion, atmosphere control and completed bond result |
| In-Situ UV Bonding | UV-compatible dispenser, curing source, light shielding and process tooling | Component position before and after curing, dispense quality and cure sequence |
| High-Force or Thermocompression Process | High-force head, heating system, force feedback and suitable tooling | Force calibration, parallelism, temperature control and bond-area uniformity |
Installed hardware is more reliable than a general option list. If the required dispenser, heater, camera or controller is absent, adding the function may involve more than a software change.
Placement Accuracy Requires More Than a Model Number
A published placement class describes a platform under specified conditions. It does not establish the current accuracy of an individual used machine.
Placement performance can change with:
Camera resolution, calibration and lighting
Condition of stages, encoders and linear motors
Bond-head parallelism and force calibration
Die dimensions and visible alignment features
Substrate fiducials and surface contrast
Thermal expansion during a heated process
Selected placement mode and production speed
Measurement equipment and sampling method
Submicron and one-micron processes also require suitable environmental control and measurement capability. A machine-placement result cannot be separated from floor vibration, temperature stability, tooling and the method used to measure the final position.
An accuracy test should record the material, placement mode, sample quantity, measurement system and statistical result. A small number of selected placements is not equivalent to a stated 3σ capability.
Flexibility Depends on the Installed Tooling
One of the practical strengths of many MRSI platforms is the ability to combine several component types and processes within one work area. The value of that flexibility depends on the machine being supplied with the correct tool banks, pickup tools, fixtures and process stations.
The tooling inventory should identify:
Pickup tools and collets
Stamping tools and epoxy wells
Tool-bank or turret positions
Wafer tables and ejector components
Waffle-pack and Gel-Pak holders
Tape feeders and tray adapters
Substrate fixtures and heated stages
Calibration plates and setup tools
A machine with the correct process stations but without its product tooling may require substantial engineering before sample production can begin. Existing recipes and fixture drawings can reduce that work when they match the new assembly.
Production Volume Changes the Model Choice
MRSI platforms cover development, product introduction and volume production. The highest placement accuracy is not automatically the most suitable choice for every project.
Development and Frequent Product Changes
The MRSI-705 and MRSI-M3 families are relevant when the work area must accept several component-input formats, tooling changes or process stations. Their flexibility can be more useful than maximum automated output during development and low- to medium-volume production.
Stable High-Volume Production
HVM configurations add material automation, parallel operations and automatic tool handling. These functions become valuable when the product and process are stable enough to keep the machine running for extended periods.
High-Volume Optical Assembly
The MRSI-LEAP and MRSI-S-HVM address newer high-volume requirements. Their published capabilities should not be assigned to earlier MRSI-HVM, MRSI-M3, MRSI-705 or MRSI-605 equipment.
For a process involving one die, one adhesive and a moderate placement tolerance, a simpler automatic die bonder may provide a more direct production route. MRSI’s multi-process flexibility is most valuable when the assembly actually uses it.
Active Alignment Is a Separate Requirement
High-precision placement and active optical alignment are not the same process.
A die bonder aligns visible die and substrate features according to the installed vision system. Active alignment moves an optical component while monitoring live optical performance, such as coupled power or insertion loss.
The MRSI-A-L is identified separately by Mycronic as an active-alignment system. A standard MRSI die bonder should not be described as performing active alignment unless the required optical measurement, feedback and motion functions are physically integrated.
Likewise, the MRSI-175Ag is a high-precision epoxy dispenser rather than a die bonder. These systems can form part of the same assembly process, but they should remain separate in the equipment list.
Used MRSI Machine Inspection
Machine Identity
Confirm the full model and suffix from the nameplate
Record serial number and manufacturing year
Identify the controller and software generation
Obtain available software backups and machine configuration files
Motion and Vision
Home and exercise all installed axes
Check encoders, stages and gantry movement
Inspect cameras, lenses and programmable lighting
Run vision calibration and repeated feature recognition
Check up-look optics when flip-chip placement is required
Force and Tool Handling
Check closed-loop force response where installed
Inspect tool banks, tool changers and tool-presence detection
Run repeated automatic tool changes
Confirm that required pickup and stamping tools are included
Process Modules
Run dispensing pumps with suitable process material
Check stamping wells and epoxy-transfer results
Test heating, temperature control and scrub for eutectic configurations
Check UV source output and curing sequence where installed
Test wafer mapping, ejector movement and die pickup from the intended input format
The completed test record should identify which processes were run with production material. Power-on, axis movement and complete process testing represent different levels of verification.
Available Machine Configuration
| Exact Model | Complete MRSI model and suffix from the current nameplate |
|---|---|
| Serial Number and Year | Confirmed from the machine and available records |
| Placement Configuration | Installed accuracy package, vision system, force range and placement head |
| Component Input | Wafer, waffle pack, Gel-Pak, tape feeder, tray or custom fixture |
| Flip-Chip Functions | Up-look camera, alignment method, compatible tools and software |
| Dispensing and Stamping | Installed pumps, controllers, needles, stamping wells and tools |
| Thermal Process | Heated stage, heated head, temperature range, scrub and atmosphere-control equipment |
| UV Process | Dispensing hardware, curing source, shielding and operating status |
| Material Automation | Standalone fixtures, wafer handler, cassette system, conveyor or installed automation |
| Tooling | Included pickup tools, stamp tools, fixtures, wafer components and calibration items |
| Software | Version, licenses, backups and available product programs |
| Test Status | As-removed, powered on, function-tested, accuracy-tested or process-tested |
Used MRSI Die Bonder Availability
Used MRSI availability changes by model, generation and installed process configuration. A general “MRSI die bonder available” description is not sufficient when the required accuracy and bonding modules have not been identified.
Send the required placement tolerance, die sizes, component-input formats, substrate drawing, bonding process, force requirement and target output through our equipment inquiry form. The requirements can then be compared with the physical machine, installed modules and included tooling.